Demo
The AI writes the command. Fixed rules decide whether it runs.
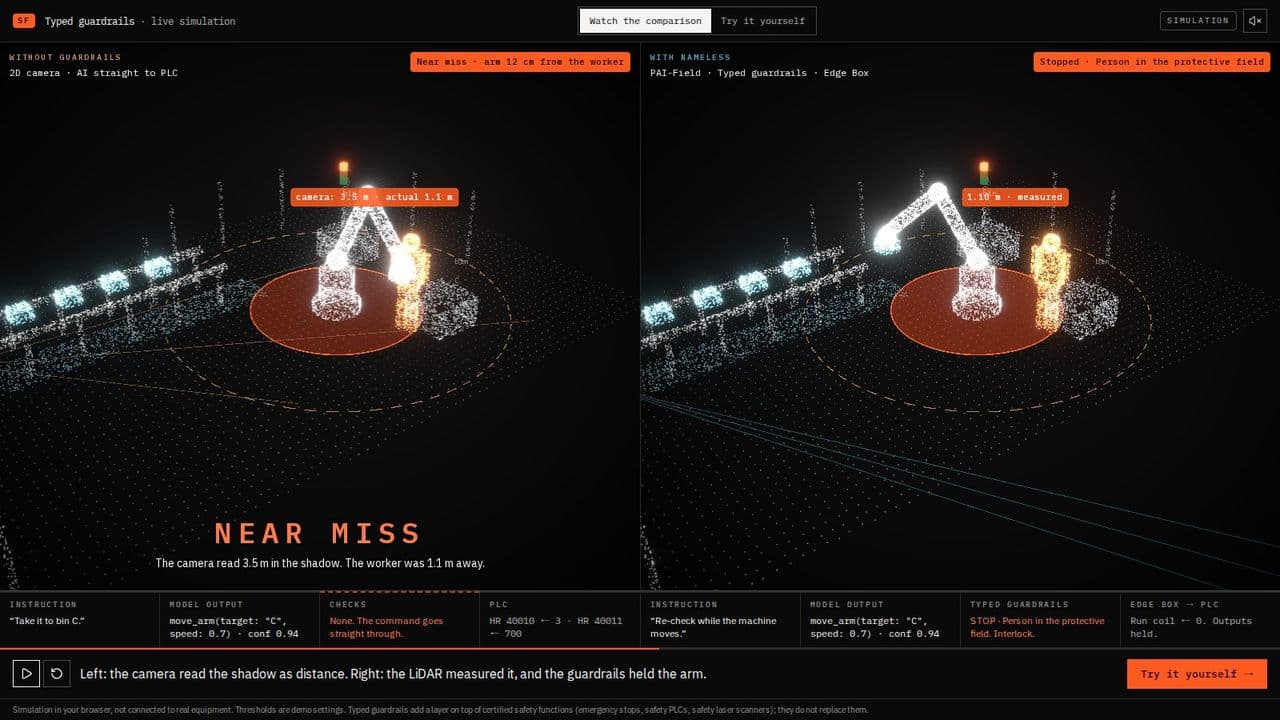
A 3D simulation of five ways an AI-driven robot cell goes wrong: a wrong distance estimate, a check that runs only once, an invalid command, a guess, and a dead sensor. Each runs on two copies of the same cell, stops at the end, and shows which rule fired, on which value, and what was written to the PLC.
 Launch the demo
Opens full screen. Runs in your browser; works best on a laptop or desktop.
What to look for
01
The decision, step by step
Every decision is shown as eight checks in evaluation order: type, stop command, interlock, confidence, point cloud, freshness, protective field, warning zone. The first one that fires decides, with the value it saw.
02
Checked again while it moves
A command that was safe when issued is re-evaluated every 100 ms. The timeline shows how many milliseconds passed between the worker crossing 1.5 m and the stop.
03
Missing data means stop
No scan, an old scan or a low confidence score stop the machine. A command that does not fit the type never reaches a register.
This is a simulation, not connected to real equipment. The thresholds in it (a 1.5 m protective field, 0.85 confidence) are demo settings, not recommendations. On a real floor, Typed guardrails sit on top of certified safety functions such as emergency stops, safety PLCs and safety laser scanners. They do not replace them.
Want to run this against your own model on real hardware?
Become a design partner